Biography
I build machine learning systems, the infrastructure that makes training and serving large models fast, adaptive and reliable.
I have spent most of my career at the intersection of systems and machine learning. As a visiting researcher in the Large Scale ML Systems Group at the University of Edinburgh, I co-authored ServerlessLLM (OSDI ‘24), a system for locality-enhanced serverless LLM inference and helped open source it. Before that, I spent four years in quantitative finance, working on model traning, inference and big data at scale. Along the way I also explored real-time 3D video reconstruction with Gaussian Splatting during my time at Entrepreneur First.
My research career started at Imperial College London, where I worked on KungFu (OSDI ‘20), a system that makes distributed Deep Learning training adaptive. My Master’s Thesis on accelerating deep learning training on distributed GPU clusters was recognized as a Distinguished Project. I graduated with First Class Honours and a Prize for Academic Excellence.
I currently work as an AI Engineer in Equities Technology at Millennium Capital in London, where I am empowering equity research with AI, with a focus on quantitative AI research.
Interests
- Machine Learning Systems
- LLM Inference & Training
- Distributed Deep Learning
- Agentic AI Systems
- 3D Computer Vision
Education & Awards
Imperial College London
Imperial College London
Imperial College London
Research
Serverless LLM Inference
Cold starts, ServerlessLLM (OSDI '24) from a co-author's seat, serverless agents and why RL needs low-latency inference.
KungFu: Adaptive Distributed Deep Learning
A distributed training library that monitors training cheaply and adapts synchronisation and even cluster size, while the model trains.
Compiler-based Back-doors
Source code that verifies as correct can still ship a back-door if the compiler miscompiles it. An attack vector, demonstrated on real programs.
Compiler Garbage Collectors, Payment Channels and Offensive Tweets
A garbage collector for a home-brewed compiler, an Ethereum micropayment channel and offensive-tweet classification.
Projects
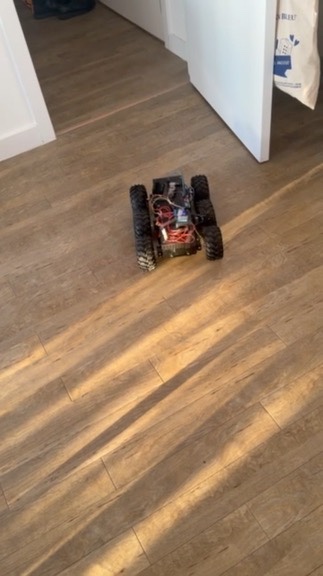
Designing a Teleoperated Garden Rover
A six-wheeled, remotely driven robot on a Jetson Nano with a Rust teleoperation stack, built to help look after a garden from far away.
Hyper-Realistic Sports: 4D Gaussian Splatting on Commodity Hardware
Running a CVPR 2024 dynamic Gaussian splatting method on a 24-camera capture I recorded myself, with no calibrated rig.
Contact
Open to collaborations and questions about any of the projects above.